Comparable three-dimensional underwater systems typically need at least six actuators to maneuver in every direction. Researchers at North Carolina State University built one that does it with two.
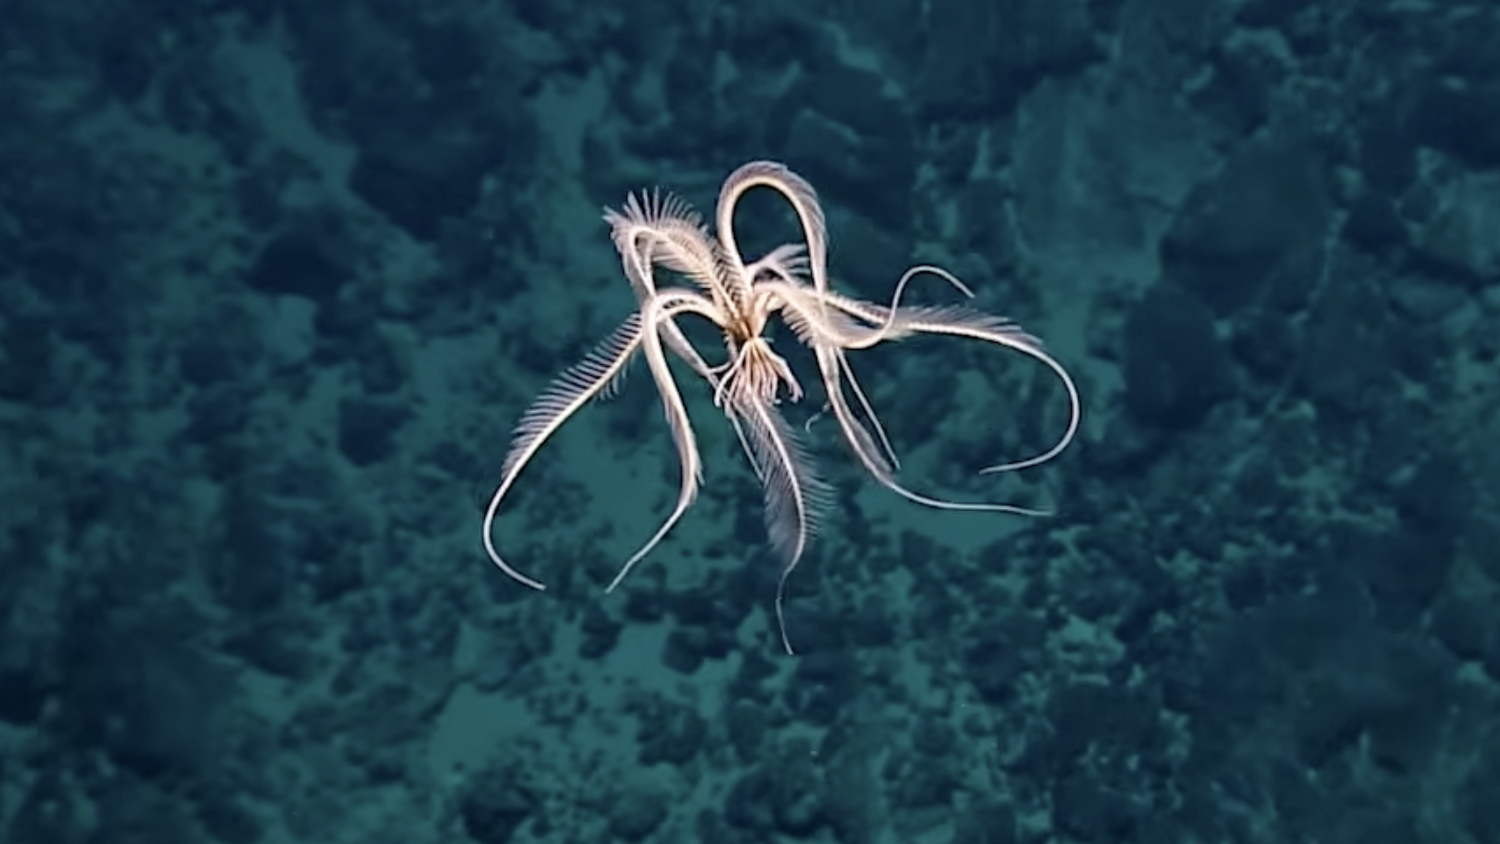
Published October 7, 2026, in Science Advances, the study by lead author Haitao Qing and colleagues describes a soft robot modeled on feather stars. These marine invertebrates coordinate multiple limbs to hover, ascend, and change direction. Earlier field deployments of bio-inspired designs, such as snake robots, demonstrate how nature-modeled locomotion translates to real-world use.
How the Robot Works
Four elastic wings and a pair of actuators replace what usually requires a much larger mechanical stack.
Four monostable wings extend from a central disk containing the two actuators. Monostable means each wing bends when actuated and springs back to its original shape when released. That elastic return does real propulsive work without a dedicated motor behind it.
Those two actuators produce three distinct movement modes:
- Jellyfish mode: Both actuators flap all wings together. Faster flapping drives the robot upward, slower flapping sustains a hover, and stopping allows it to sink.
- Fish mode: One actuator flutters a single wing like a tailfin, generating forward or backward travel depending on the control pattern.
- Rotor mode: Rapid alternation between the two actuators creates asymmetric wing movement, rotating the robot around its central axis for steering.
Why “Mechanical Intelligence” Matters
Shifting complexity from motors and code into geometry and materials is the central engineering insight of this design.
Mechanical intelligence, as the NC State team applies it, means the robot’s structure handles control work that would otherwise require more electronics, sensors, or software. Think of it as the difference between a Swiss Army knife and a toolbox: one carefully shaped object covers situations that would otherwise demand separate tools. Research into adjacent platforms, such as the humanoid robot, illustrates how the broader field is reckoning with that same complexity-versus-capability tension.
Jie Yin, professor of mechanical and aerospace engineering at NC State and the study’s corresponding author, described the approach directly: “One exciting aspect of this work is that it demonstrates how we can create robotic devices with an incredible range of motion using a minimum number of actuators, by taking advantage of intelligent design techniques.”
The tradeoff is real. Simpler hardware is genuinely useful, but the available research does not establish how this robot performs on speed, payload capacity, endurance, or stability in turbulent open water. Those remain open questions.
Demonstrated Uses and Next Steps
Lab results show exploration, object lifting, and cooperative robot tasks, though field deployment has no confirmed timeline.
In lab demonstrations, researchers mounted a camera on the robot for underwater exploration. They also showed it lifting objects alone and cooperatively with other robots. University-led projects like the robotic knee exoskeleton from the University of Michigan reflect a similar push to translate controlled lab results into practical applications.
The platform extends earlier NC State work on a manta-ray-inspired swimmer that moved quickly but lacked comparable three-dimensional control. Future plans include a fully wireless version and cross-disciplinary applications, though the available reports do not provide a deployment timeline.
The work was funded in part by the Office of Naval Research, with collaborating institutions including the University of Virginia and UC Riverside (DOI: 10.1126/sciadv.aeg9211).
As soft robotics matures, more research groups are exploring whether smarter material design can absorb complexity that once demanded more motors, more sensors, and more code. Whether that approach holds up outside the lab is the next question worth watching.