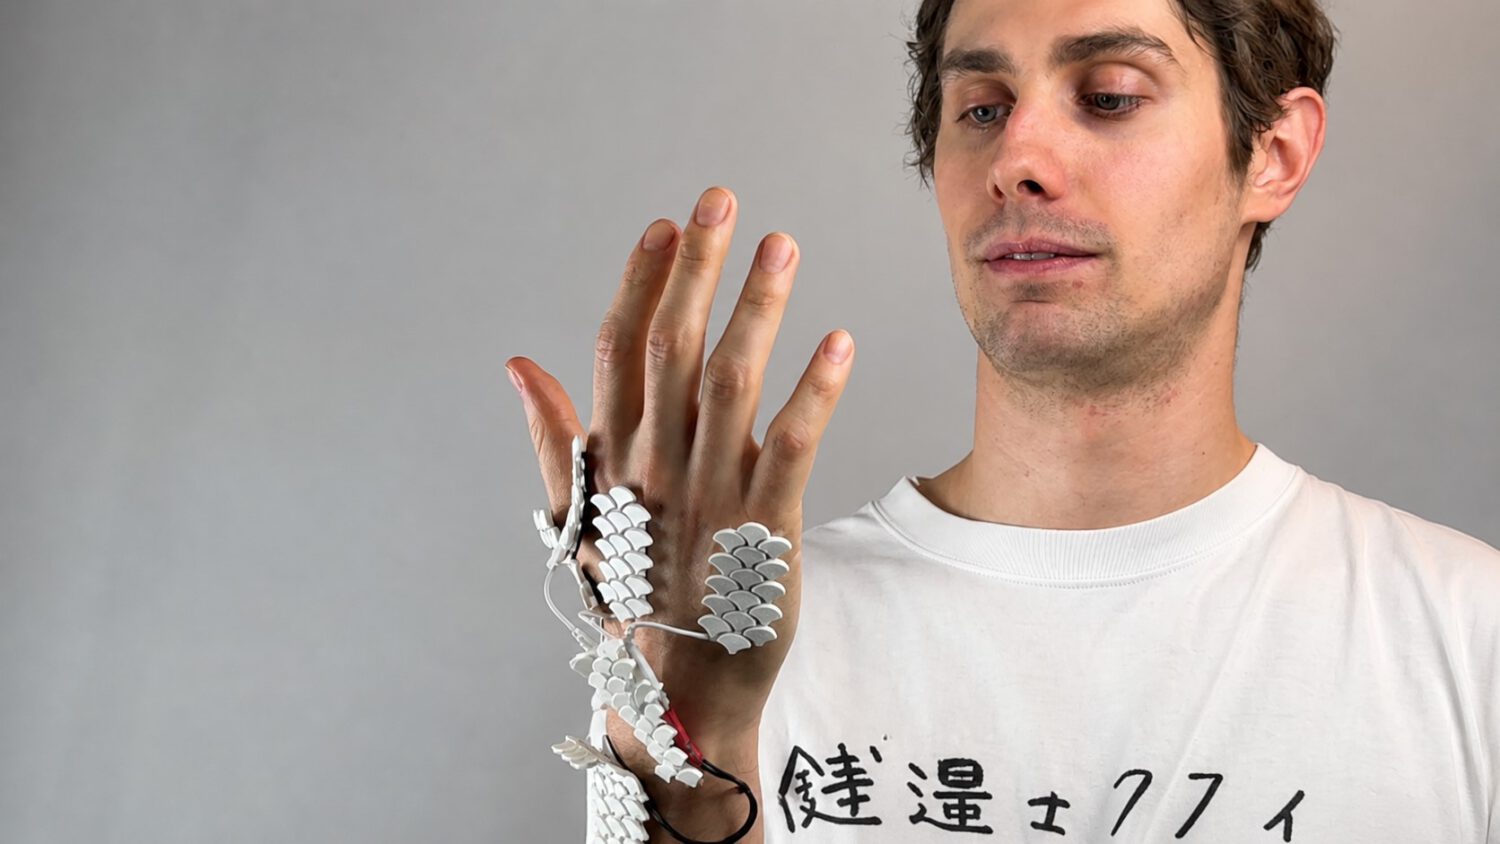
Say a word, watch your fingers move. That is the basic premise behind Human Operator, a wearable prototype built by a six-person team during MIT Hard Mode 2026, a 48-hour hardware-and-AI hackathon where it won the Learn Track. The team includes Peter He, Valdemar Danry, Daniel Kaijzer, Yutong Wu, Ashley Neall, and Sean Hardesty Lewis. Whether the project’s participants are all MIT students has not been independently confirmed beyond the team’s connection to the MIT Hard Mode event.
How the Hardware Chain Works
The system links a head-mounted camera, Anthropic’s Claude, an Arduino relay, and skin electrodes into a single movement pipeline.
A head-mounted camera feeds first-person visual context into the system while you speak a command. Anthropic’s Claude processes both inputs, determines a movement sequence, and passes instructions to an Arduino-controlled relay that routes signals to EMS electrodes on the wearer’s arm or wrist.
EMS, short for electrical muscle stimulation, delivers electrical pulses through the skin to targeted muscles, causing them to contract and produce movement in the fingers or wrist. Reported demonstrations include waving, forming an “OK” sign, and guiding a hand through simple piano notes: discrete gestures, not a recital.
What the System Cannot Do
Moving someone’s fingers through a movement sequence is not the same as building their coordination, timing, or muscle memory.
No available source establishes that Human Operator can teach arbitrary complex skills, replace conventional practice, or produce lasting learning outcomes. The prototype guides selected movements; the team’s stated ambition includes training and skill assistance, but those remain goals rather than verified results.
Guiding your hand through a movement is closer to a GPS routing your fingers than to genuinely teaching you to navigate. The motion happens once. Independent competence does not follow automatically.
Where the Research Could Lead
EMS has a long history in physical therapy; the novelty here is connecting it to a multimodal AI system that responds to voice and visual context.
The team’s stated directions include physical rehabilitation, accessibility for people with motor impairments, and prosthetics research. Using guided stimulation to help a patient experience a target movement has precedent in physical therapy and rehabilitation science, though that history requires its own clinical sourcing. Human Operator’s contribution is attempting to connect that stimulation to a system that interprets voice commands and visual context at the same time.
Significant open questions remain before any of those applications become practical. Safety testing for unintended muscle contractions and individual tolerance differences would require rigorous study. Electrode placement also varies across anatomies, adding another layer of complexity a relay-based hackathon prototype has not addressed.
The privacy implications of a head-mounted camera capturing surroundings, documents, and bystanders are unresolved. Language model errors in a chatbot produce a wrong answer; the same error here could produce an unwanted physical movement in your body. That is a meaningfully different kind of failure.
A Proof-of-Concept Worth Watching
Human Operator is not a commercial product, an approved medical device, or a clinically validated tool; the available sources describe it as a working prototype.
Human Operator illustrates both the appeal and the real stakes of giving AI a physical interface with the human body. Whether the approach eventually produces tools that help people move, recover, or learn remains an open research question, and one that 48 hours in a hackathon cannot settle.